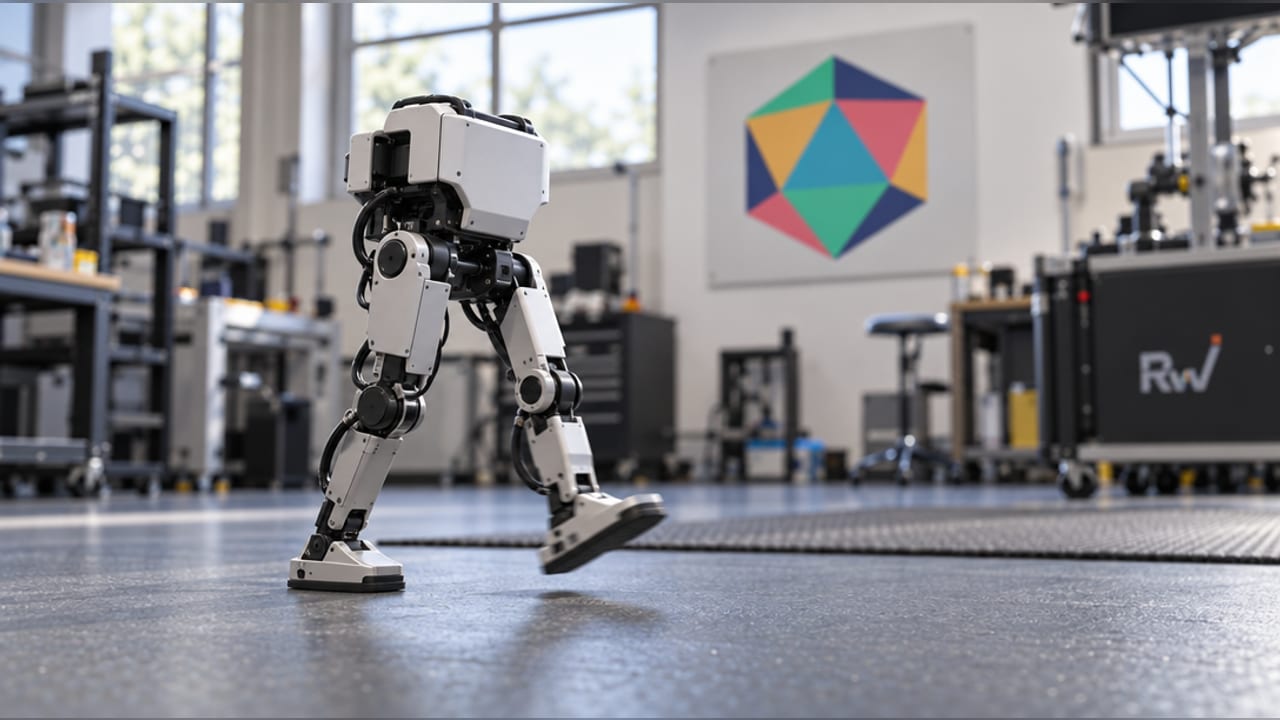
Co-founder Matthieu Lapeyre's open-robotics bet now has a 4,096-environment training recipe, ONNX export and steps for deploying a learned gait on the physical biped.
        By [RuntimeWire Staff](https://runtimewire.com/author/runtimewire-staff)
        · Published
        · Updated

Primary source: [Hugging Face Newsroom](https://huggingface.co/blog/nvidia/microduck-isaac-lab-sim-to-real)
Why it matters #
Pollen is turning an affordable biped into a hands-on test of open robotics: developers can train, export and share locomotion policies, while the GPU requirement and real-world transfer still set the practical limits.
Pollen Robotics has published a path for training its Microduck biped in simulation and running the resulting walking policy on the physical robot, extending co-founder Matthieu Lapeyre's long-running open-robotics project from shared hardware into shared behaviors.…
When you purchase through links in our articles, we may earn a small commission. This doesn’t affect our editorial independence.