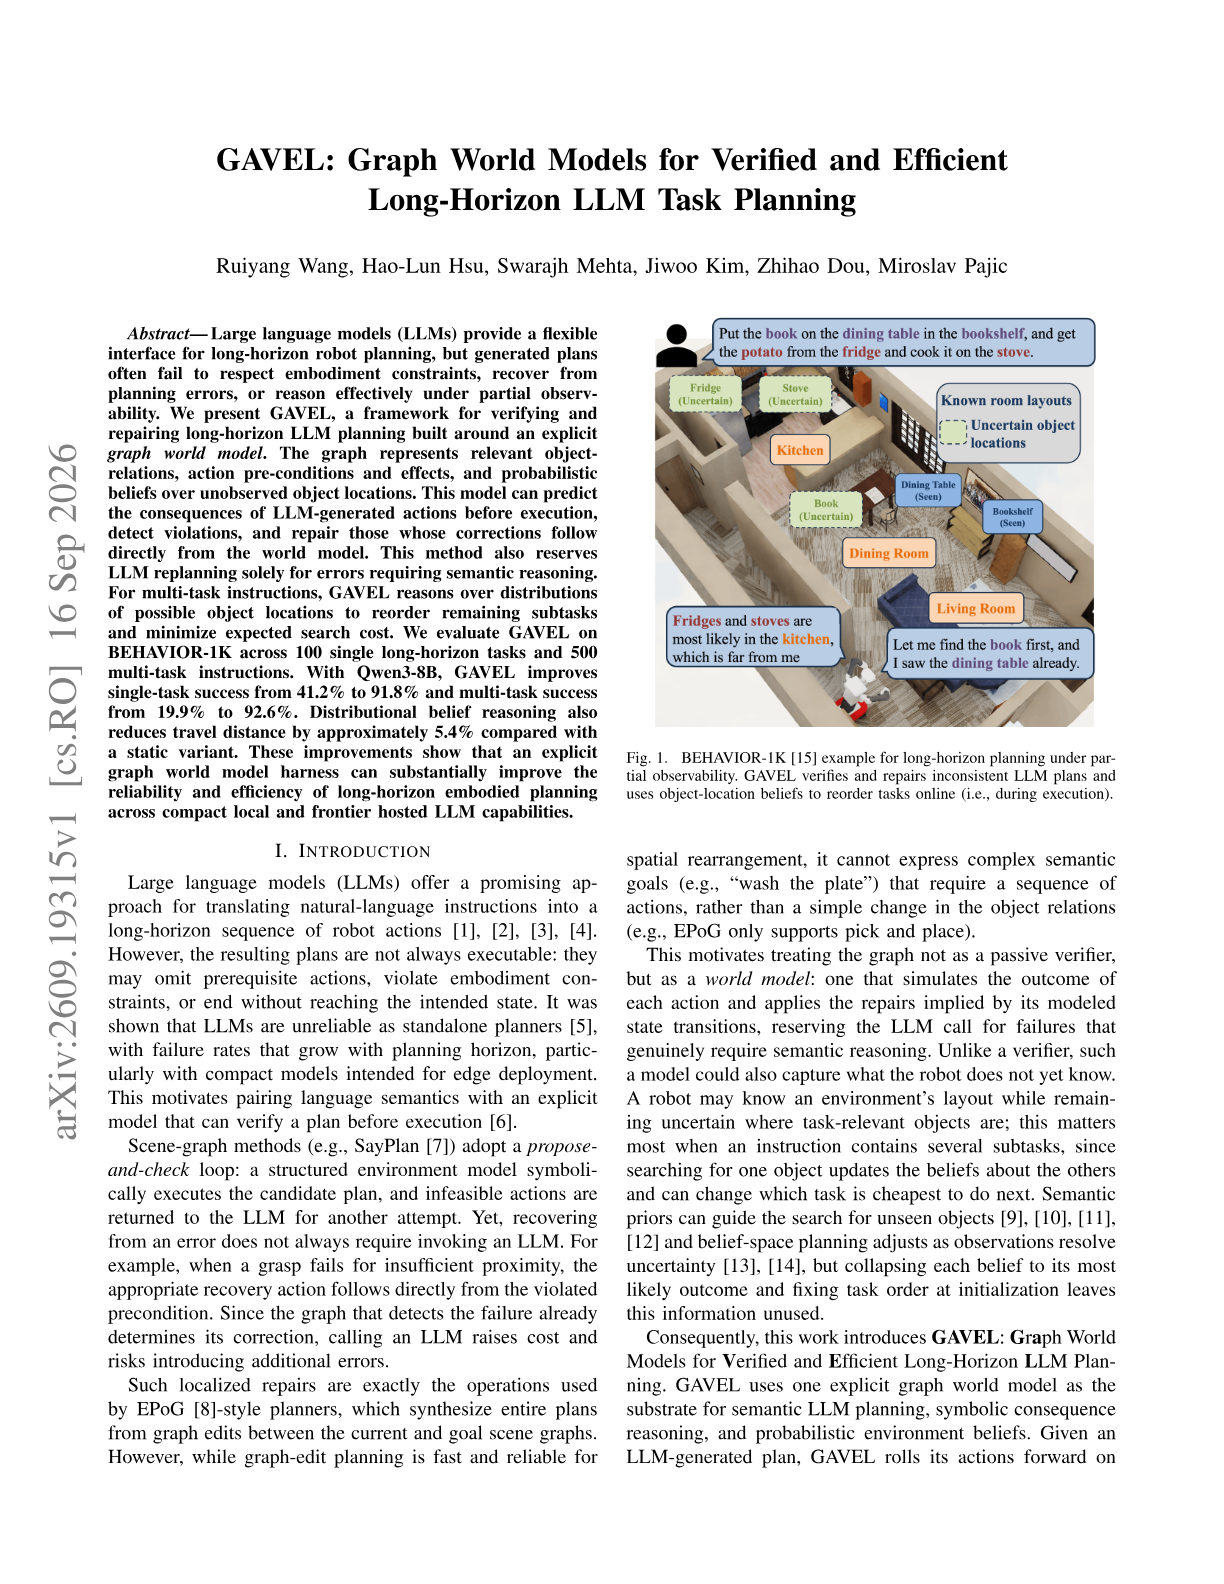
Ruiyang Wang and colleagues present GAVEL, which verifies and repairs long-horizon LLM robot plans against an explicit graph world model holding object relations, action preconditions and effects, and probabilistic beliefs over unobserved locations.
Ask this paper #
Single-task success goes from 41.2 to 91.8 percent. With Qwen3-8B on BEHAVIOR-1K across 100 long-horizon tasks; multi-task success rises from 19.9 to 92.6 percent across 500 multi-task instructions.
The graph predicts consequences before execution. Violations are detected and repaired directly when the correction follows from the world model, and LLM replanning is reserved for errors that need semantic reasoning.
Belief reasoning reorders subtasks. Reasoning over distributions of possible object locations reduces expected search cost and cuts travel distance about 5.4 percent against a static variant.
The gain holds for a compact model. Most of the improvement comes from the harness rather than model capability, which is the argument for putting the world model outside the LLM.
Abstract #
Large language models (LLMs) provide a flexible interface for long-horizon robot planning, but generated plans often fail to respect embodiment constraints, recover from planning errors, or reason effectively under partial observability. We present GAVEL, a framework for verifying and repairing long-horizon LLM planning built around an explicit graph world model. The graph represents relevant object-relations, action pre-conditions and effects, and probabilistic beliefs over unobserved object locations. This model can predict the consequences of LLM-generated actions before execution, detect violations, and repair those whose corrections follow directly from the world model. This method also reserves LLM replanning solely for errors requiring semantic reasoning. For multi-task instructions, GAVEL reasons over distributions of possible object locations to reorder remaining subtasks and minimize expected search cost. We evaluate GAVEL on BEHAVIOR-1K across 100 single long-horizon tasks and 500 multi-task instructions. With Qwen3-8B, GAVEL improves single-task success from 41.2% to 91.8% and multi-task success from 19.9% to 92.6%. Distributional belief reasoning also reduces travel distance by approximately 5.4% compared with a static variant. These improvements show that an explicit graph world model harness can substantially improve the reliability and efficiency of long-horizon embodied planning across compact and frontier hosted LLM capabilities.