Built on Newton and MuJoCo Warp. Open source under Apache-2.0. You
pip install alloy-engine
Your agent
Build and train
*<your task>*with Alloy
see prompt #
Install alloy-engine with pip (Python 3.11 or 3.12, in a virtual environment). Read its docs: run python -m alloy.docs, or fetch https://alloy.argonrobotics.ai/llms.txt. Then build <your task> in many parallel worlds: start from the closest ready-made environment in the docs and change it step by step. Train a policy until it succeeds, check sim.health() after every run, and report the success rate.
Built for agents. #
- Docs in the package
python -m alloy.docsshows them on your machine. - Build a new task in minutes Agents built new training tasks from the docs in minutes.
- Health in every world Tells a physics failure from a policy failure.
- Settings choose themselves Solvers and steps are picked;
sim.routes()says why.
Key features. #
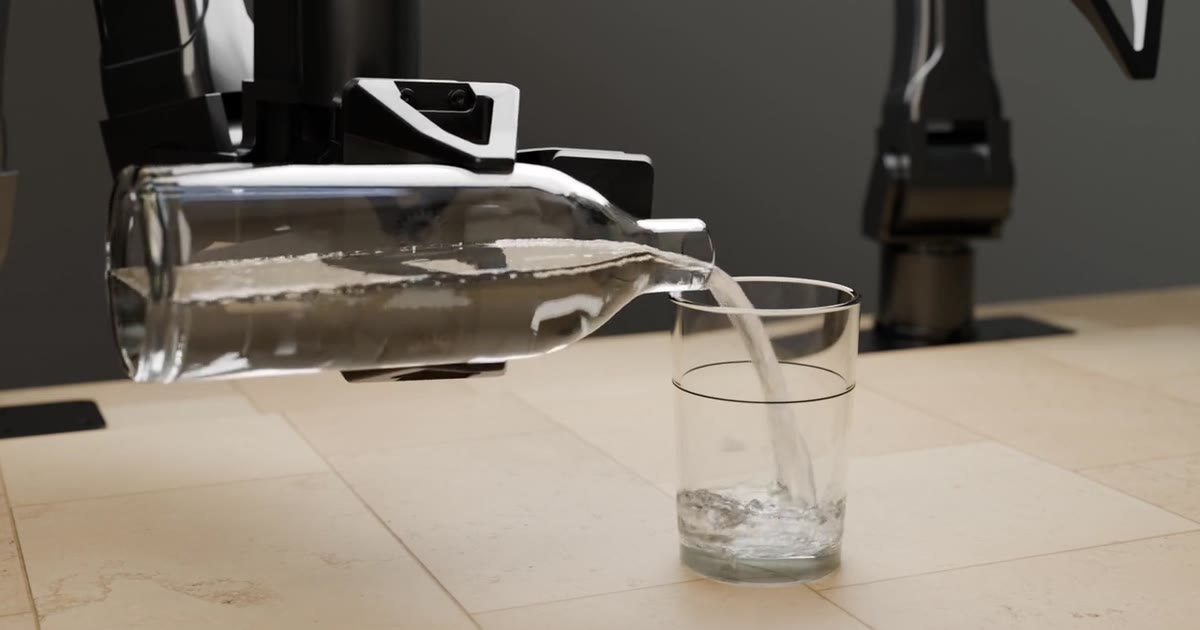
- Many materials, one scene Robots, cloth, cables, liquids, sand and soft bodies, stepped together. Cloth and a cable beside a robot run slowly.
- GPU or CPU The same script, renderer included, runs on an NVIDIA GPU or the CPU.
- A camera for every world Colour, depth and segmentation of every world at once.
- Robots ready to go Arms, a hand, a quadruped and two humanoids, with RL and demo recording.
- Assets and tasks included 5,423 library objects, 9 ready-made tasks (pick-and-place, pouring, drawers, cloth folding) and quadruped walking.
source & further reading
alloy.argonrobotics.ai — original article